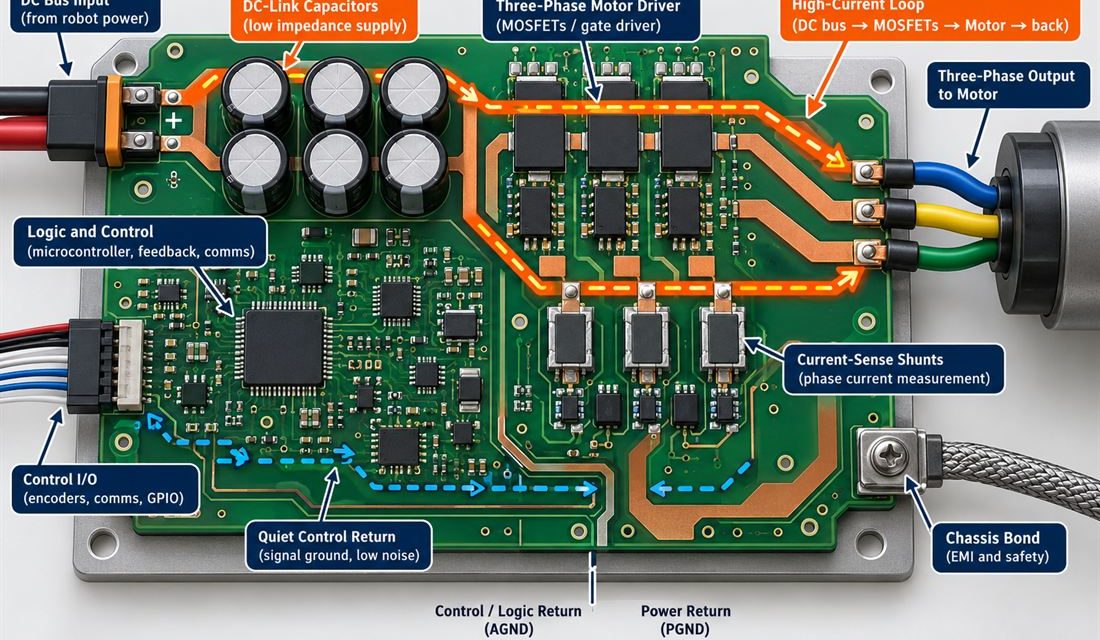
Table of Contents Why motion errors begin in the power loop Shape the motor-current path Protect the control return Validate acceleration and braking Release a serviceable joint controller A robot joint can miss a taught position even when the control algorithm is unchanged. The hidden cause in a Robotics PCB is often a power-integrity problem:...
