HomeTag

Industrial Robotics - KKPCB

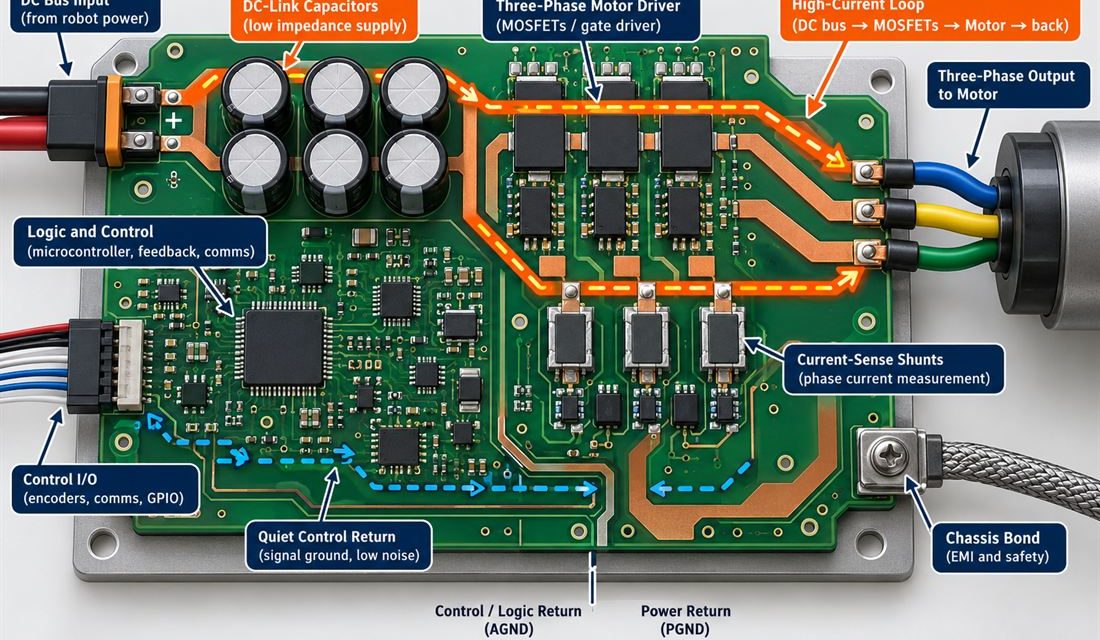
Robotics PCB Motor Drive Layout: Keeping Torque Commands Clean

Table of Contents Why motion errors begin in the power loop Shape the motor-current path Protect the control return Validate acceleration and braking Release a serviceable joint controller A robot joint can miss a taught position even when the control algorithm is unchanged. The hidden cause in a Robotics PCB is often a power-integrity problem:...
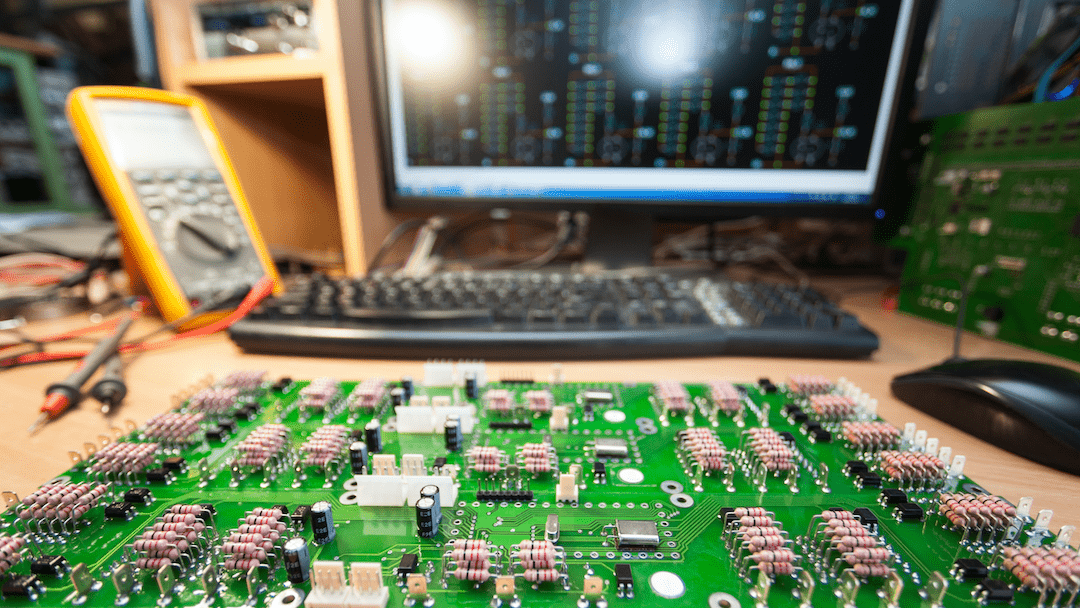
Robotics PCB Architecture: High-Density, High-Speed, and High-Reliability Engineering for Autonomous and Industrial Robotics

Introduction: PCB Architecture as the Core of Robotics Systems In modern autonomous robotics and industrial robotics, the design of Robotics PCB architecture plays a decisive role in determining system performance, real-time responsiveness, and operational reliability. As robots become more intelligent, compact, and interconnected, the demand for high-density, high-speed, and high-reliability PCB solutions continues to grow....