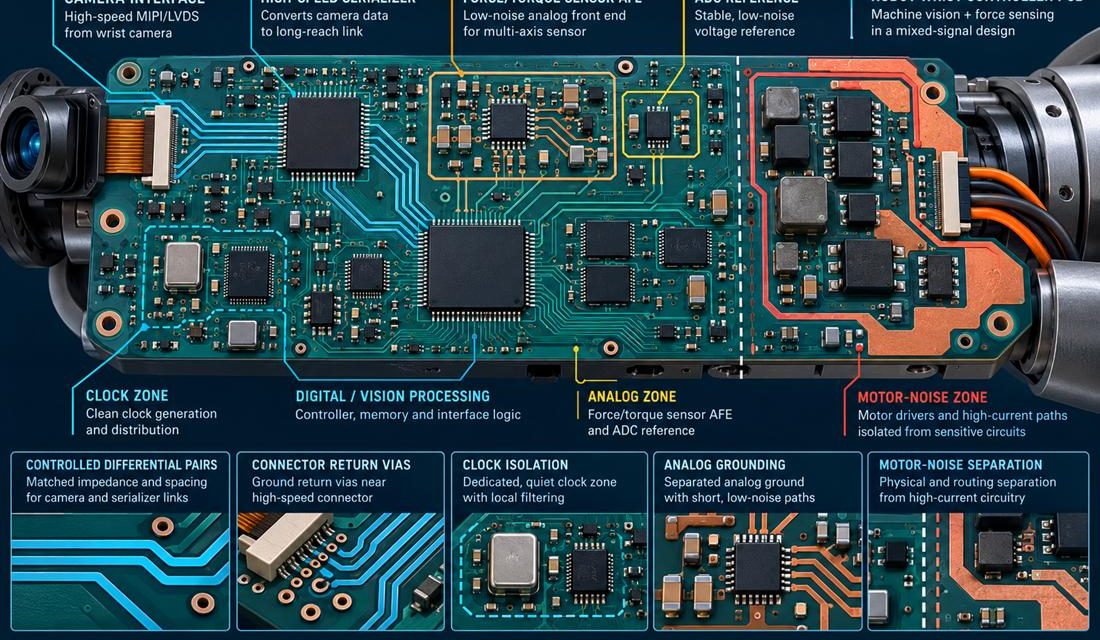
Table of Contents Why vision and force signals fight on one board Partition clocks, analog, and motor noise Protect high-speed launches Calibrate the sensor chain Release a wrist module A robot wrist that combines a camera, a force/torque sensor, and a motor interface has three different definitions of “clean data.” The camera needs controlled differential...
